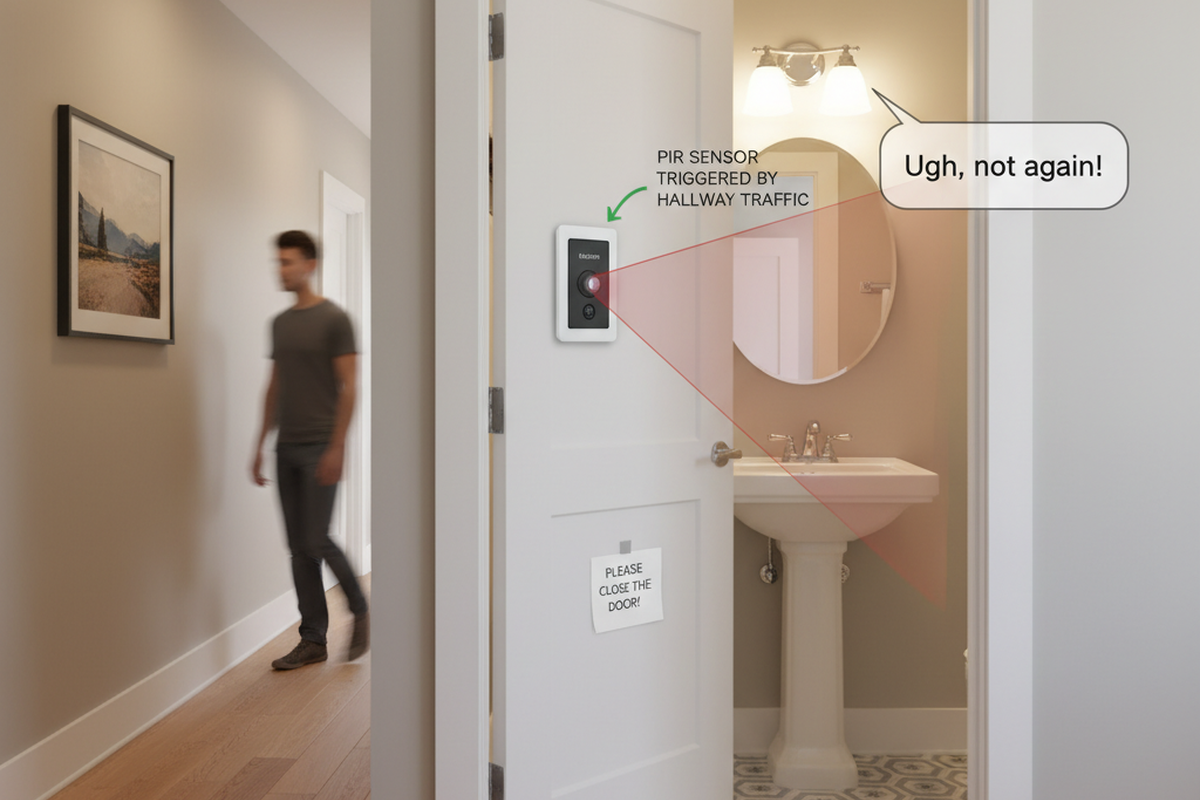
The promise of a smart home often dies at two in the morning, when a cat trips a motion sensor and floods the living room with light. It dies when the dog wandering the hall activates a switch meant only for people, or when a curtain shifting in the breeze is mistaken for occupancy. Within weeks, the frustrated homeowner has either dialed down the sensor’s sensitivity until it misses actual people or disabled the automation entirely. The intended efficiency becomes a nuisance, and expensive hardware sits idle.
This isn’t a failure of technology. It’s a failure of configuration. The physics that allows a sensor to detect movement doesn’t inherently distinguish a German Shepherd from a human adult. But the differences in how those two subjects occupy space, generate heat, and move are real and exploitable. With the right setup, those differences can be turned into reliable discrimination.
The solution isn’t more sensitive hardware or expensive AI-powered cameras. It’s the disciplined application of three mechanical strategies: shaping the sensor’s vertical field of view, deliberately choosing a mounting height, and tuning sensitivity thresholds. Used together, these techniques slash false triggers from pets and incidental movement while preserving rock-solid human detection. The result is automation that works.
The Abandonment Problem: When Pets Break Automation
The cycle is depressingly familiar. A new motion sensor is installed with factory settings, often at a convenient height instead of an optimal one. For a few days, it works perfectly. Lights snap on when someone enters a room. The system feels intelligent.
Then the cat begins its nightly patrol. The dog restlessly moves from one sleeping spot to another. The sensor triggers, lights turn on, and sleep is disturbed. At first, it’s just an annoyance. But with dozens of false activations a week, the problem becomes systemic. The homeowner fights back by lowering the sensitivity. This helps, for a while. But soon the system starts missing actual human presence—a person moving slowly, entering from an odd angle, or walking at the edge of the detection zone. The automation has become unreliable in both directions.
Giving up is the only rational response. The promised convenience has become a maintenance chore. The hardware stays on the wall, inert, as the household returns to flipping switches by hand. This outcome isn’t rare; it’s the dominant failure mode for motion control in homes with pets. The loss isn’t just the cost of the hardware, but the ongoing energy waste the system was meant to prevent.
How Motion Sensors Detect Anything at All
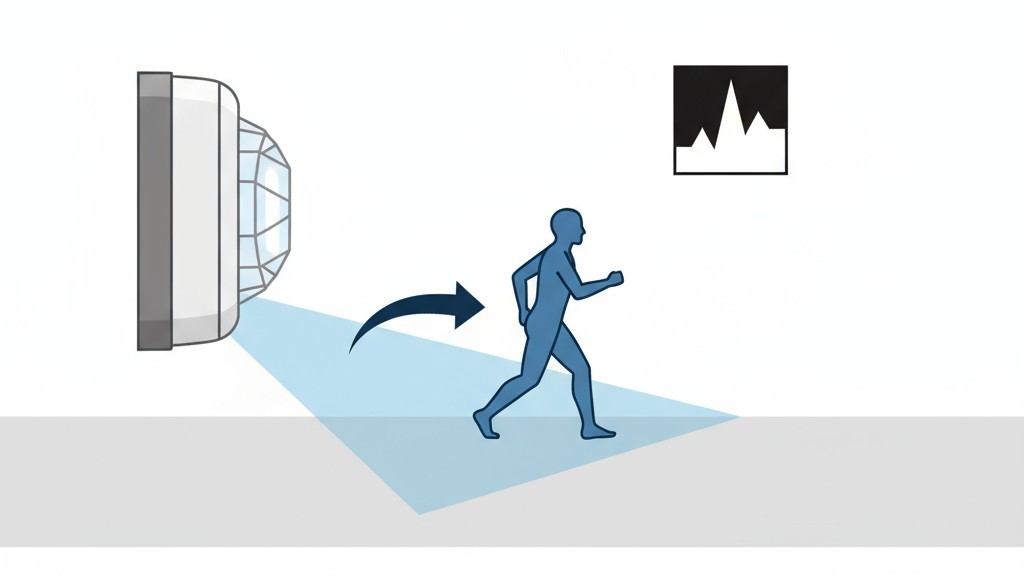
Passive infrared (PIR) sensors, the workhorse of residential automation, are essentially heat-differential detectors. Every object warmer than absolute zero radiates infrared energy. A PIR sensor uses a special pyroelectric element, typically split into two or more zones, to measure changes in this ambient infrared field. When a warm body moves from one zone to another, the element generates a tiny voltage differential. If that signal crosses a set threshold, the sensor reports a detection.
人感センサーを活用した省エネソリューションをお探しですか?
PIR人感センサー、人感センサー搭載省エネ製品、人感センサースイッチ、商業施設向けOccupancy/Vacancy(在室/不在)ソリューションについては、お気軽にお問い合わせください。
A PIR sensor doesn’t “see” in any visual sense. It registers thermal movement. This is why it detects a cat as readily as a person. Both are warm bodies that create a temperature contrast against a cooler wall or floor. As the cat moves, it shifts between the sensor’s detection zones, generating the exact same kind of signal a human would. The signal from a person might be stronger, but the fundamental event is identical. The sensor has no inherent concept of size or height. It responds to change.
Microwave sensors use a different principle but run into the same problem. They emit a continuous, low-power radio frequency signal and listen for Doppler shifts in the reflection. Any object moving toward or away from the sensor will alter the frequency of the reflected wave. A dog trotting across the room creates a Doppler shift just as measurable as a person’s. Like the PIR, the microwave sensor only knows that something is moving, not what is moving.
By default, both sensor types are designed to be inclusive. They are built to catch any movement, which is ideal for a security system but disastrous for home automation that must respond only to people. Without specific constraints, the sensor will dutifully report every pet, every shifting curtain, and even a large insect crawling directly across its lens.
The Exploitable Differences Between Pets and People
So how do we teach a simple sensor to be smarter? We exploit the physical differences between people and pets.
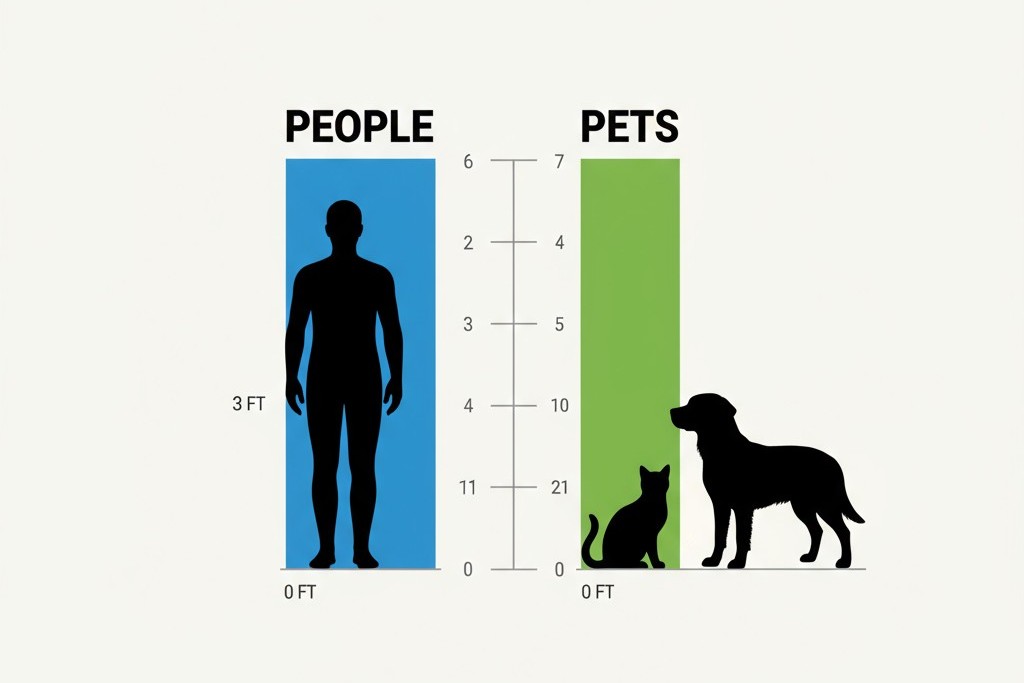
The first and most reliable difference is vertical positioning. A standing or seated adult occupies a height range that a cat or small dog simply doesn’t. Even a large dog on all fours keeps its body heat and bulk much lower to the ground than a human torso. Most human movement occurs above three feet from the floor; most pet movement is concentrated in the lowest two feet. This vertical separation is our primary advantage.
The second difference is the size of the heat signature. A human body is a larger infrared source than a small animal, distributed over a greater vertical area. This means a person will typically produce a stronger, more sustained signal. This factor is less reliable than height, however, because distance complicates things. A cat very close to the sensor can produce a signal as strong as a person farther away. Size is a useful secondary filter, but it can’t be the only one.
The third difference, movement pattern, is the weakest of all. People and pets both move at variable speeds. A person tiptoeing at night might move as slowly as a cat on the prowl. A dog bolting for the door moves faster than a person walking. While some advanced systems try to analyze gait, these methods are too fragile for most homes. For our purposes, movement pattern is not a reliable variable.
Vertical Field-of-View Shaping: Engineering Blind Zones
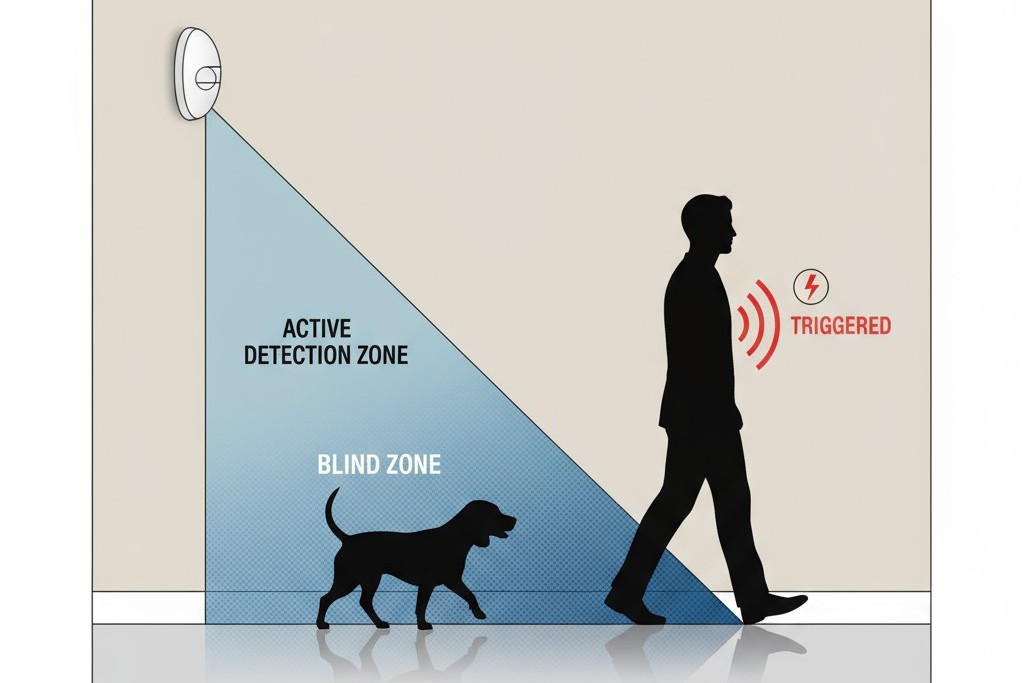
The most effective strategy is to create an engineered blind spot. Field-of-view shaping deliberately restricts the sensor’s detection area to exclude the vertical zone where pets live and move. This is a mechanical solution, not a software filter.
A PIR sensor’s Fresnel lens is segmented to focus infrared energy from specific angles onto the sensing element. By physically masking parts of this lens, or by using a lens designed with intentional dead zones, we can make the sensor blind to the lower portion of its field of view. The floor-level area is simply removed from the detection geometry.
A properly shaped “pet-immune” sensor has a blind zone extending from the floor up to about two and a half feet. A cat walking directly underneath it is invisible; the infrared energy it emits never gets focused onto the sensor’s active zones. But when a person walks into the same space, their torso and head move through the active upper zones, and the sensor triggers instantly. This isn’t a probability game; it’s a geometric certainty. The sensor cannot see the floor, just as a camera pointed at the ceiling cannot.
This technique is remarkably effective, but it has limits. One is a very large dog, whose head and shoulders might just breach the lower edge of the active zone. The other is a climbing pet. A cat that leaps onto a countertop or the back of a sofa will elevate itself into the active field and trigger the sensor. These aren’t failures of the method, but an acknowledgment of its boundaries.
Mounting Height as the Foundation
The higher a sensor is mounted, the steeper its downward viewing angle becomes. This steep angle compresses the vertical field of view, effectively raising the lower boundary of detection. At six feet, a sensor might have a blind zone of two feet off the floor. Mount that same sensor at eight feet, and the blind zone could extend to nearly three feet. Height is the foundation of pet immunity.
This is why installation guides for pet-immune sensors are so specific about mounting height. A sensor mounted at standard switch height (around four feet) has a shallow downward angle and almost no floor blind zone. It will see everything. The same sensor mounted at seven or eight feet gains significant immunity because the pet’s heat signature, concentrated near the floor, never intersects the sensor’s active detection cone.
Rayzeek人感センサーのポートフォリオを見る.
お探しの製品が見つかりませんか?ご安心ください。課題を解決する手段は常に複数存在します。当社の製品ポートフォリオのいずれかがお役に立つかもしれません。
The trade-off is a slight reduction in horizontal coverage, as a high-mounted sensor creates a small dead zone directly beneath it. For most rooms, this is a non-issue. In very large spaces, it may be better to use two strategically placed sensors rather than one unit at a compromised height.
If you can’t drill holes, get creative. Use a tall bookshelf, a freestanding pole, or a bracket on a piece of furniture to get the sensor to the necessary elevation. The mounting method is secondary; the height is everything.
Sensitivity Tiers: The Final Dial
Sensitivity defines the minimum signal strength needed to trigger a detection. Think of it as a volume knob. Lowering the sensitivity raises the required signal threshold, meaning a larger or closer heat source is needed to trigger an event.
After field-of-view shaping and mounting height have done the heavy lifting, sensitivity tuning acts as a final filter. It helps manage edge cases, like a large dog whose shoulder just grazes the active zone or a cat that occasionally climbs onto a low table. By setting the sensitivity just high enough to reliably detect a human but below the threshold for these minor pet signals, you gain an extra margin of error.
こちらの商品もおすすめです

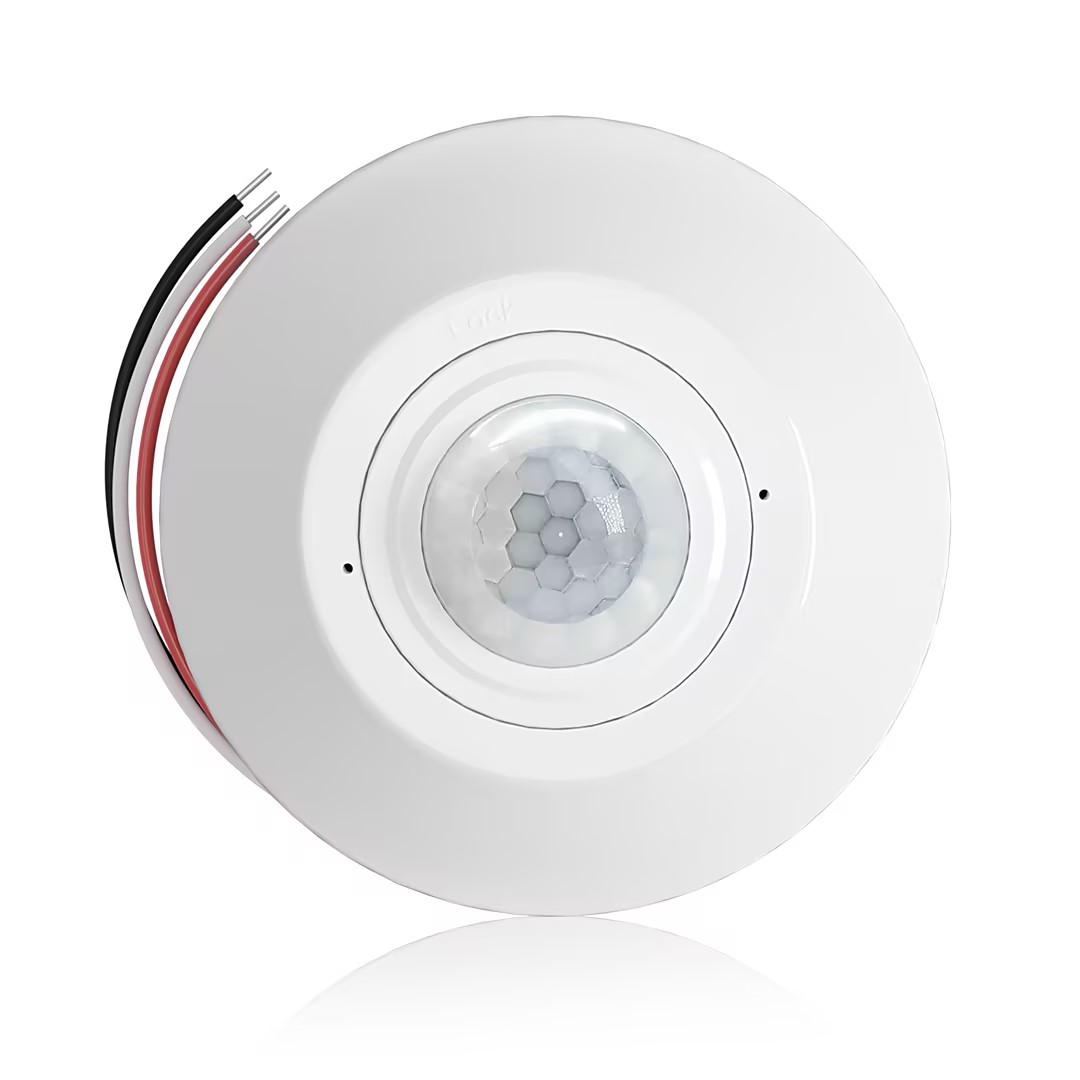
- 無電圧接点リレー出力付き天井取り付け型PIR人感センサー
- 12/24VDCまたは12/24VAC低電圧電源
- EMS、HVAC、および建物制御入力用COM、NO、NC絶縁リレー接点
- 低電圧DC天井埋め込み型マイクロ波人感センサースイッチ
- 10~30 VDC範囲の12 VDC / 24 VDC入力
- 調整可能なタイムラグ、照度(Lux)閾値、感度を備えた最大動作電流10A仕様
- 高負荷対応型 埋込型天井取付けマイクロ波人感センサースイッチ
- 100-265 VAC 商用電源入力、10Aモデル
- 調整可能なタイムラグ、照度(Lux)閾値、感度を備えた5.8 GHzマイクロ波検知
- 埋込型天井取付けマイクロ波人感センサースイッチ
- 100-265 VAC商用電圧入力、5Aモデル
- 調整可能なタイムラグ、照度(Lux)閾値、感度を備えた5.8 GHzマイクロ波検知
- 220V電源対応 天井取付けRZ037 PIR(赤外線)人感センサー調光器
- 定格負荷660W、最大動作電流3A
- LUXボタンによる照度センサーのON/OFFおよびユーザー設定の調光明るさ制御
- 110V電源対応 天井取付けRZ037 PIR(赤外線)人感センサー調光器
- 定格負荷330W、最大動作電流3A
- LUXボタンによる照度センサーのON/OFFおよびユーザー設定の調光明るさ制御
- 低電圧DC対応 天井取付けマイクロ波人感センサースイッチ
- 10~30 VDC範囲の12 VDC / 24 VDC入力
- 調整可能なタイムラグ、照度(Lux)閾値、感度を備えた最大動作電流10A仕様
- 高負荷対応 天井取付型マイクロ波人感センサースイッチ
- 100-265 VAC 商用電源入力、10Aモデル
- 調整可能なタイムラグ、照度(Lux)閾値、感度を備えた5.8 GHzマイクロ波検知
- 天井取り付け型マイクロ波人感センサースイッチ
- 100-265 VAC商用電圧入力、5Aモデル
- 調整可能なタイムラグ、照度(Lux)閾値、感度を備えた5.8 GHzマイクロ波検知
- 低電圧DC埋込型天井PIR人感センサースイッチ
- 10~30 VDC範囲の12 VDC / 24 VDC入力
- 最大動作電流10A(調整可能なタイムラグ、照度閾値、感度設定付き)
- 高負荷対応 埋込型天井PIR人感センサースイッチ
- 100-265 VAC 商用電源入力、10Aモデル
- 360度検知(調整可能なタイムラグ、照度閾値、感度設定付き)
- 埋込型天井PIR人感センサースイッチ
- 100-265 VAC商用電圧入力、5Aモデル
- 360度検知(調整可能なタイムラグ、照度閾値、感度設定付き)
- 屋内用照明ON/OFF制御ワイヤレススイッチ&受信機キット
- 100-230VAC、50/60Hz、定格電流5A受信機
- 2.4GHz通信対応 CR2032電池駆動ワイヤレススイッチ
- Occupancy(自動点灯/自動消灯)
- 12–24V DC (10–30VDC)、最大10A
- 360°検知エリア、直径8–12m
- タイムラグ 15秒–30分
- 照度センサー オフ/15/25/35 Lux
- 高/低感度
- 自動点灯/自動消灯人感モード
- 100–265V AC, 10A(中性線必須)
- 360°検知範囲、検知直径8–12 m
- タイムデレイ15秒–30分、Lux OFF/15/25/35、感度 高/低
- 自動点灯/自動消灯人感モード
- 100–265V AC, 5A(中性線必須)
- 360°検知範囲、検知直径8–12 m
- タイムデレイ15秒–30分、Lux OFF/15/25/35、感度 高/低
- 100V-230VAC
- 伝送距離:最大20m
- ワイヤレス人感センサー
- 有線制御
Finding the sweet spot requires iteration, not calculation. The difference in signal strength between a small person at the edge of the room and a large dog near the center can be slim. Set it too low, and you’ll miss people. Set it too high, and the dog triggers it. The goal is to find the point where human detection is reliable and pet triggers are reduced to a tolerable, near-zero frequency. Some advanced sensors even allow for different sensitivity levels for day and night, tightening the rules when false triggers are most disruptive.
Why Microwave-Only Fails in Small Homes
Microwave sensors are sometimes marketed as a superior solution, theoretically capable of analyzing an object’s velocity and mass from its Doppler signature. In a wide-open space, this can work. In a small, furnished room, the physics breaks down.
The problem is multipath reflection. The sensor’s signal doesn’t just travel to the target and back; it bounces off walls, furniture, and appliances. These reflections create a noisy, chaotic signal environment. A small moving cat can appear much larger due to constructive interference from reflections, while a person can appear smaller due to destructive interference. The sensor’s ability to discriminate based on size becomes completely unreliable. In a typical kitchen or bedroom, a microwave-only sensor often generates more false pet triggers than a poorly configured PIR.
Dual-technology sensors, which combine PIR and microwave and require both to agree before triggering, are a far better approach. The PIR provides the robust geometric discrimination from height and field-of-view shaping. The microwave adds a secondary confirmation of movement. A cat on the floor might fool the microwave sensor with distorted reflections, but it will be invisible to the PIR’s masked-off lower field. Since both don’t trigger, the alarm is suppressed, filtering out the vast majority of false positives.
Testing Configuration With Intentional Paths
A configured sensor is an untested hypothesis. To validate it, you need a structured walk-through.
The test procedure is simple:
- Walk through the coverage area at a normal pace from every entrance. Confirm the sensor triggers reliably.
- Test the boundaries. Walk slowly and at the far edges of the room to find the limits of human detection.
- Let your pets roam freely. Watch to see if their normal paths, especially directly under the sensor, cause a trigger.
- If possible, encourage climbing. Coax the cat onto the sofa or a low shelf to see if that specific action creates a false positive.
- Adjust and repeat. If a large dog still triggers the sensor, try lowering the sensitivity a notch or raising the mounting height by six inches, then run the test again.
This iterative, real-world testing provides feedback far more valuable than any spec sheet. Remember the goal is not just a technically perfect system, but one that operates without stressing your animals. A setup that works but makes the dog anxious about sudden lights has failed. The true sign of success is a system so well-tuned that your pets don’t even know it’s there.